01
Collective Dynamics
Investigating how local interactions generate information propagation, coordinated motion, and emergent collective behavior across large multi-agent systems.
Robotics · Controls · Autonomous Systems
GOCI Robotics conducts foundational and applied research in robotics, autonomous systems, control theory, and multi-agent coordination. We investigate the principles governing intelligent and collective robotic systems and translate those insights toward technologies for complex real-world environments.
Foundational Research
Our research examines the mathematical, computational, and physical principles that determine how autonomous agents sense, communicate, coordinate, and respond to their environments.
Investigating how local interactions generate information propagation, coordinated motion, and emergent collective behavior across large multi-agent systems.
Developing and analyzing control architectures for networked autonomous systems operating with asymmetric interactions, communication constraints, delays, and incomplete information.
Studying mechanisms underlying collective biological behavior and translating those principles into models and control strategies for engineered robotic systems.
Exploring planning and decision-making methods that allow robotic systems to operate safely and effectively under uncertainty and changing environmental conditions.
Developing control and planning approaches that combine autonomous performance with explicit safety, stability, and operational constraints.
Studying how information travels through networked robotic and biological systems and how network structure influences propagation speed, distortion, stability, and collective response.
Research Approach
GOCI Robotics approaches autonomy as both a fundamental research problem and an engineering challenge. Understanding the mechanisms that govern stability, information flow, decision-making, and collective behavior can provide new approaches to designing autonomous systems that operate beyond the limitations of conventional centralized architectures.
Our work combines mathematical modeling, control theory, numerical simulation, robotic experimentation, and engineering design. This allows fundamental questions about autonomous and networked systems to be investigated while maintaining a pathway toward practical robotic applications.
Technical Capabilities
GOCI combines theoretical research with experience designing, analyzing, testing, and operating complex engineered systems.
Application Areas
Our research is motivated by robotic systems that must operate with limited information, uncertain environments, communication constraints, and high requirements for reliability and autonomy.
Autonomous spacecraft, robotic servicing, manipulation, coordinated spacecraft systems, and distributed space architectures.
Distributed and bio-inspired autonomy for surface and underwater robotic systems operating in communication-limited environments.
Autonomous navigation, multi-agent coordination, manipulation, and intelligent robotic systems for complex terrestrial environments.
Founder
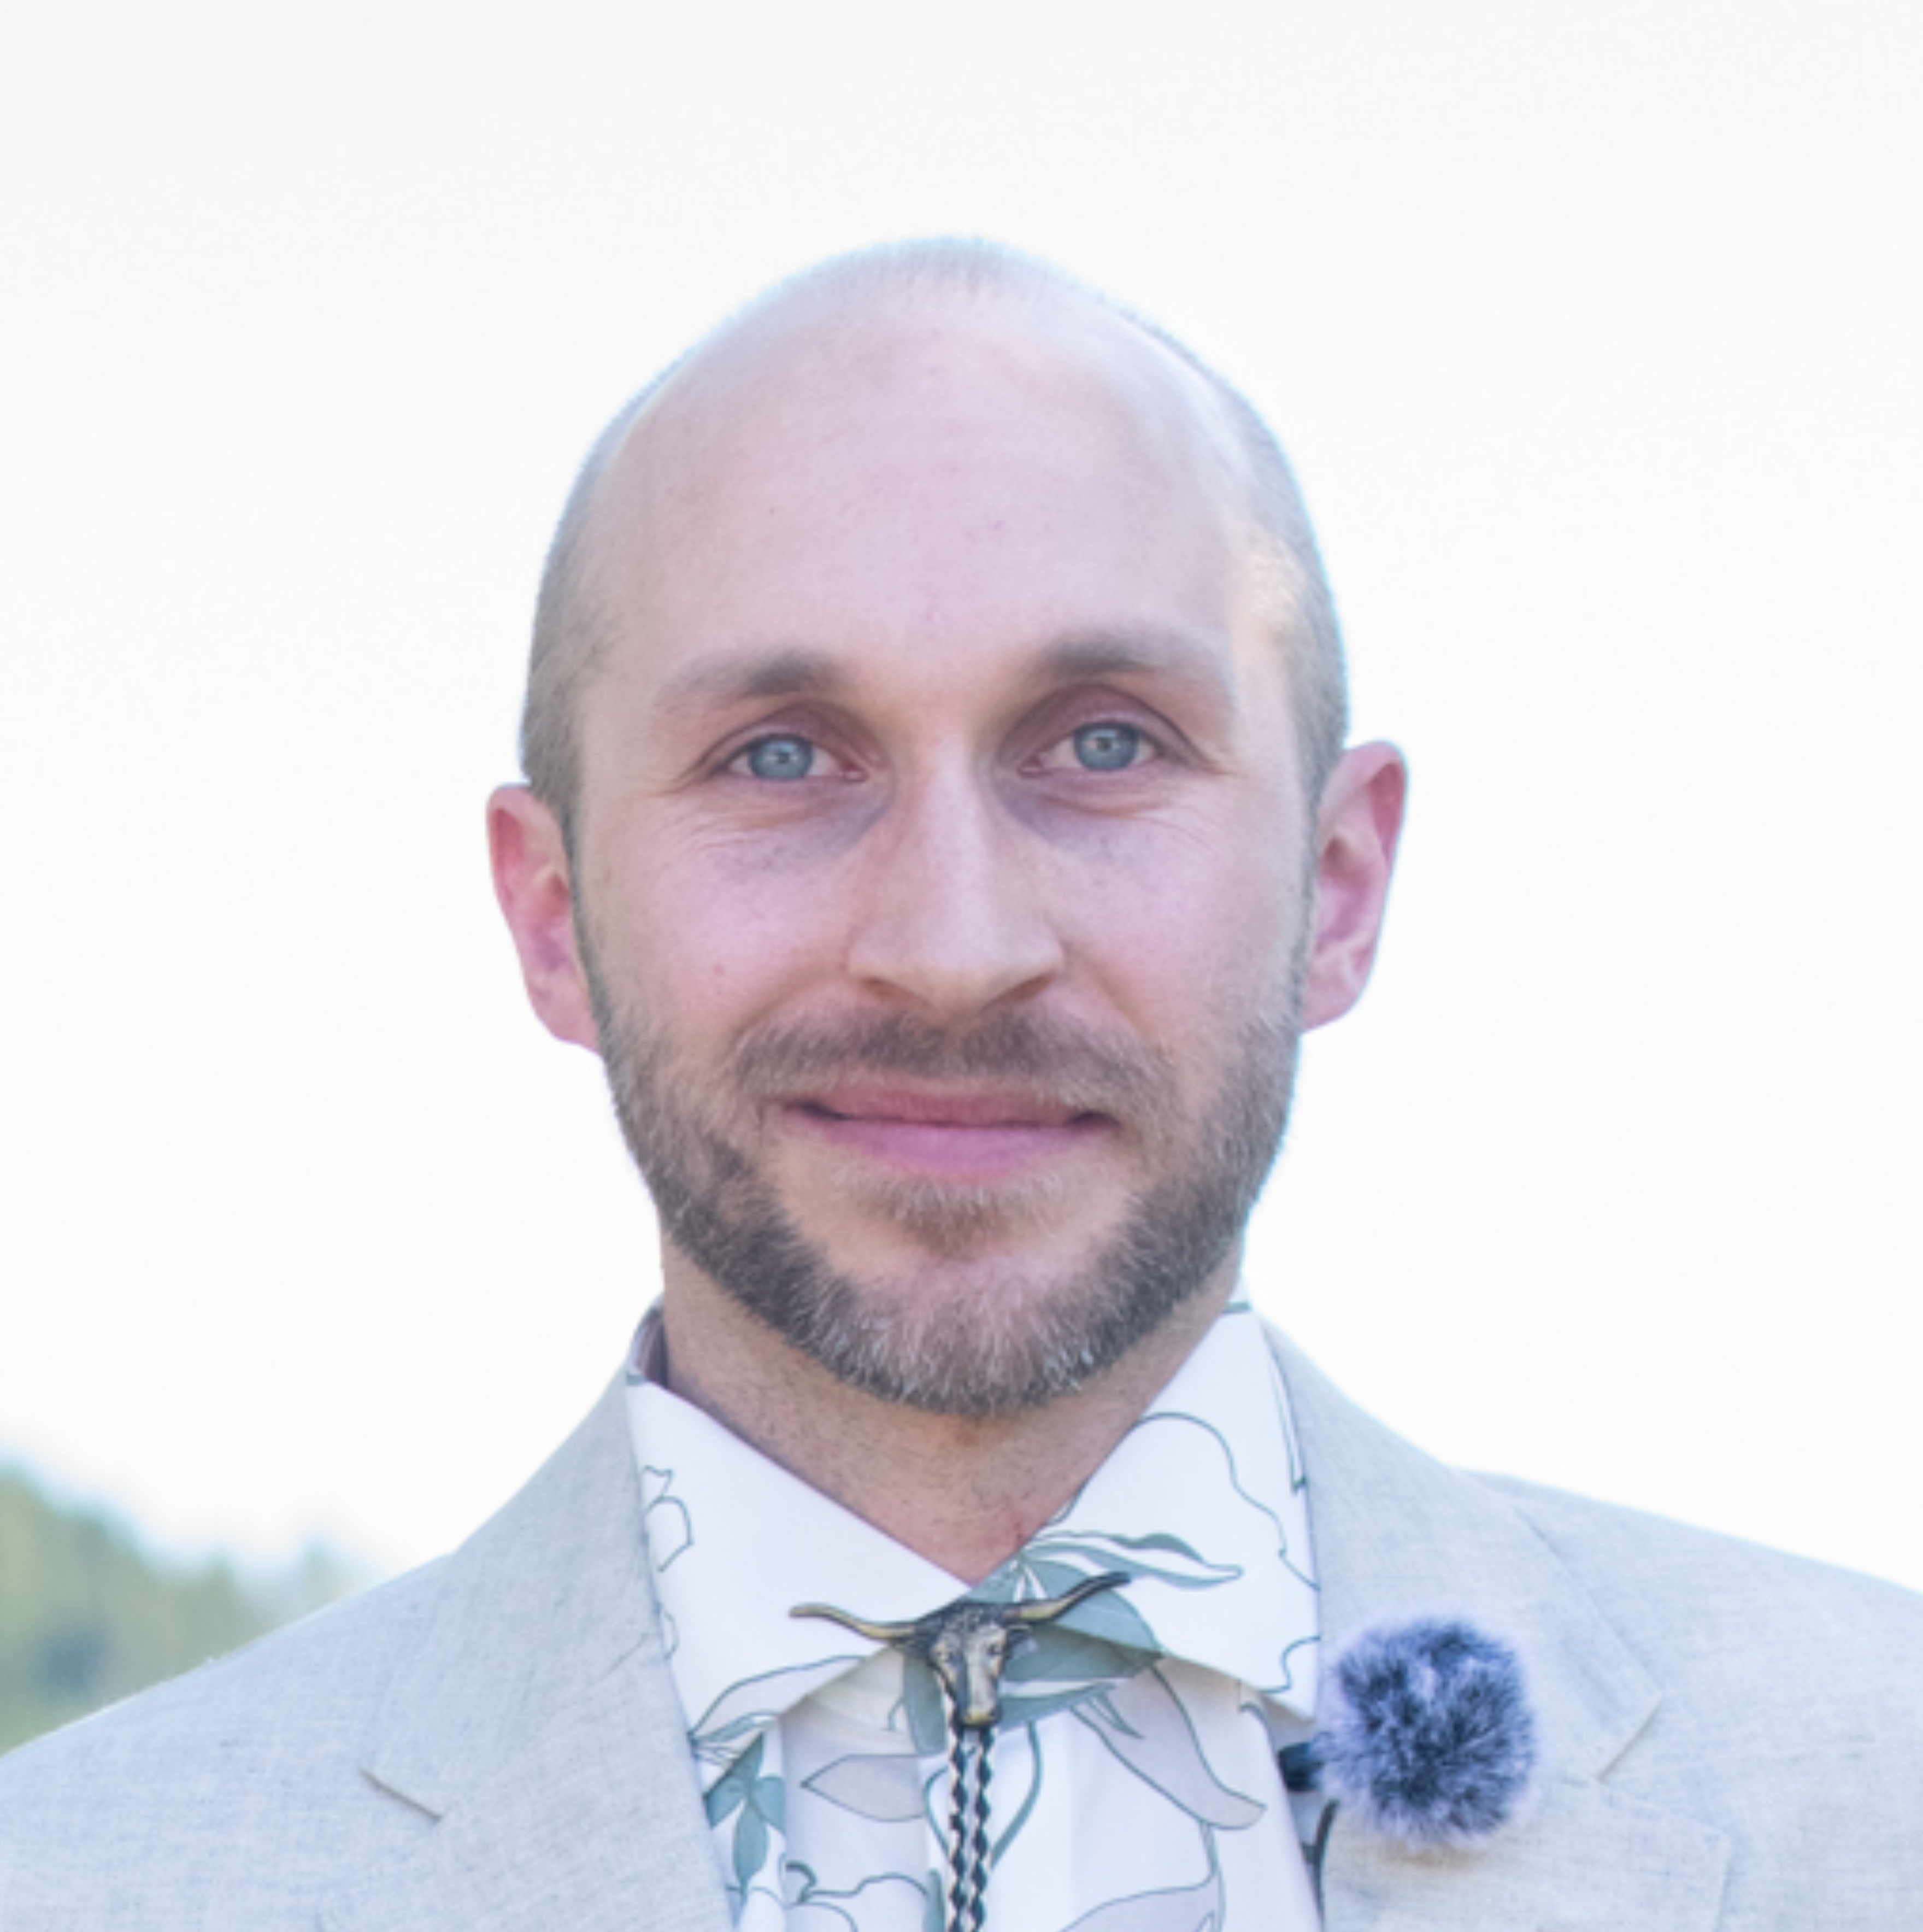
Founder & Principal Investigator
William Howe is the founder and Principal Investigator of GOCI Robotics, LLC and a Ph.D. candidate in Mechanical Engineering at the University of Washington. His current research focuses on robotics, autonomous systems, control theory, and multi-agent coordination, including the fundamental mechanisms governing information propagation and collective behavior in networked robotic systems.
Prior to his doctoral research, William accumulated more than a decade of engineering experience across the design, prototyping, testing, manufacturing, integration, and operation of complex engineered systems. His industry experience includes electromechanical systems, control and automation, system validation, and aerospace engineering, and culminated in leading the Mechanical Systems Design team for Blue Origin's New Shepard launch vehicle through its first human flight.
This combination of research and industry experience shapes GOCI Robotics' approach: investigate fundamental questions in autonomy and control while maintaining a direct connection to the engineering realities required to transition new ideas into reliable robotic systems.
Contact
GOCI Robotics is interested in research collaborations, government-sponsored research, and partnerships focused on advancing autonomous and robotic systems.
info@gocirobotics.com